Exoskeleton
Intermediate Team
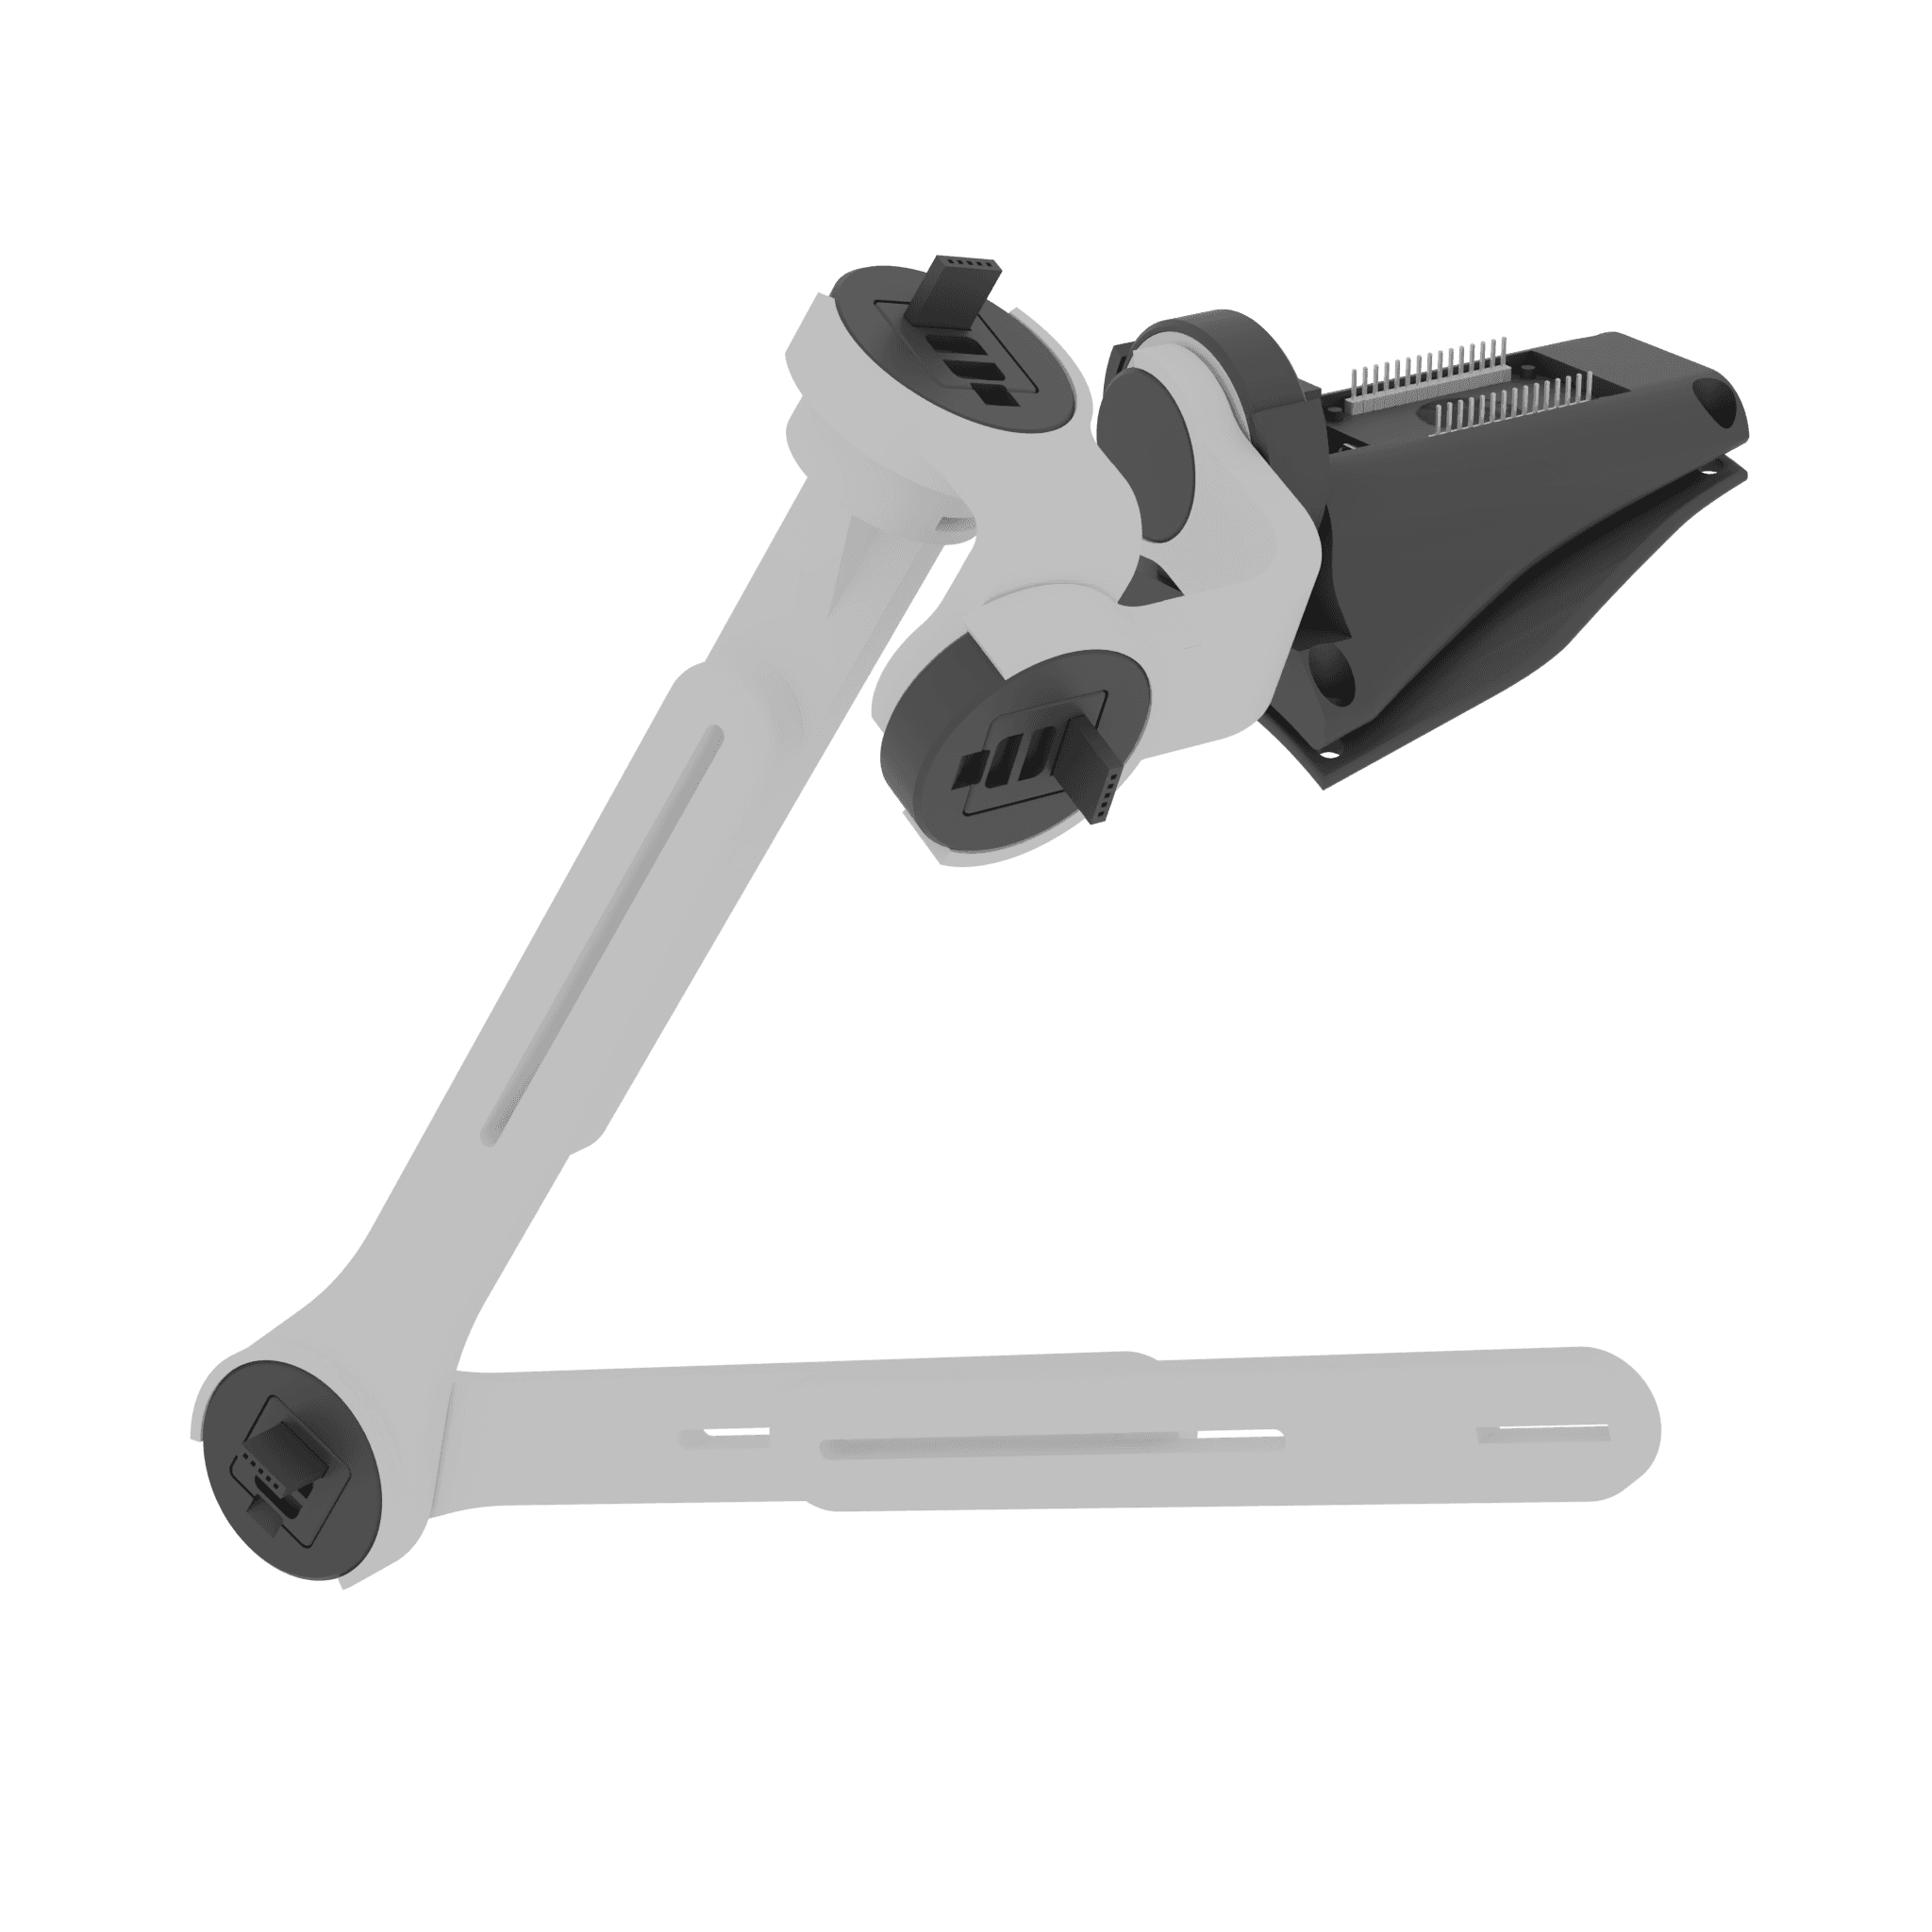
A digital render of the second "Leader Arm" prototype.
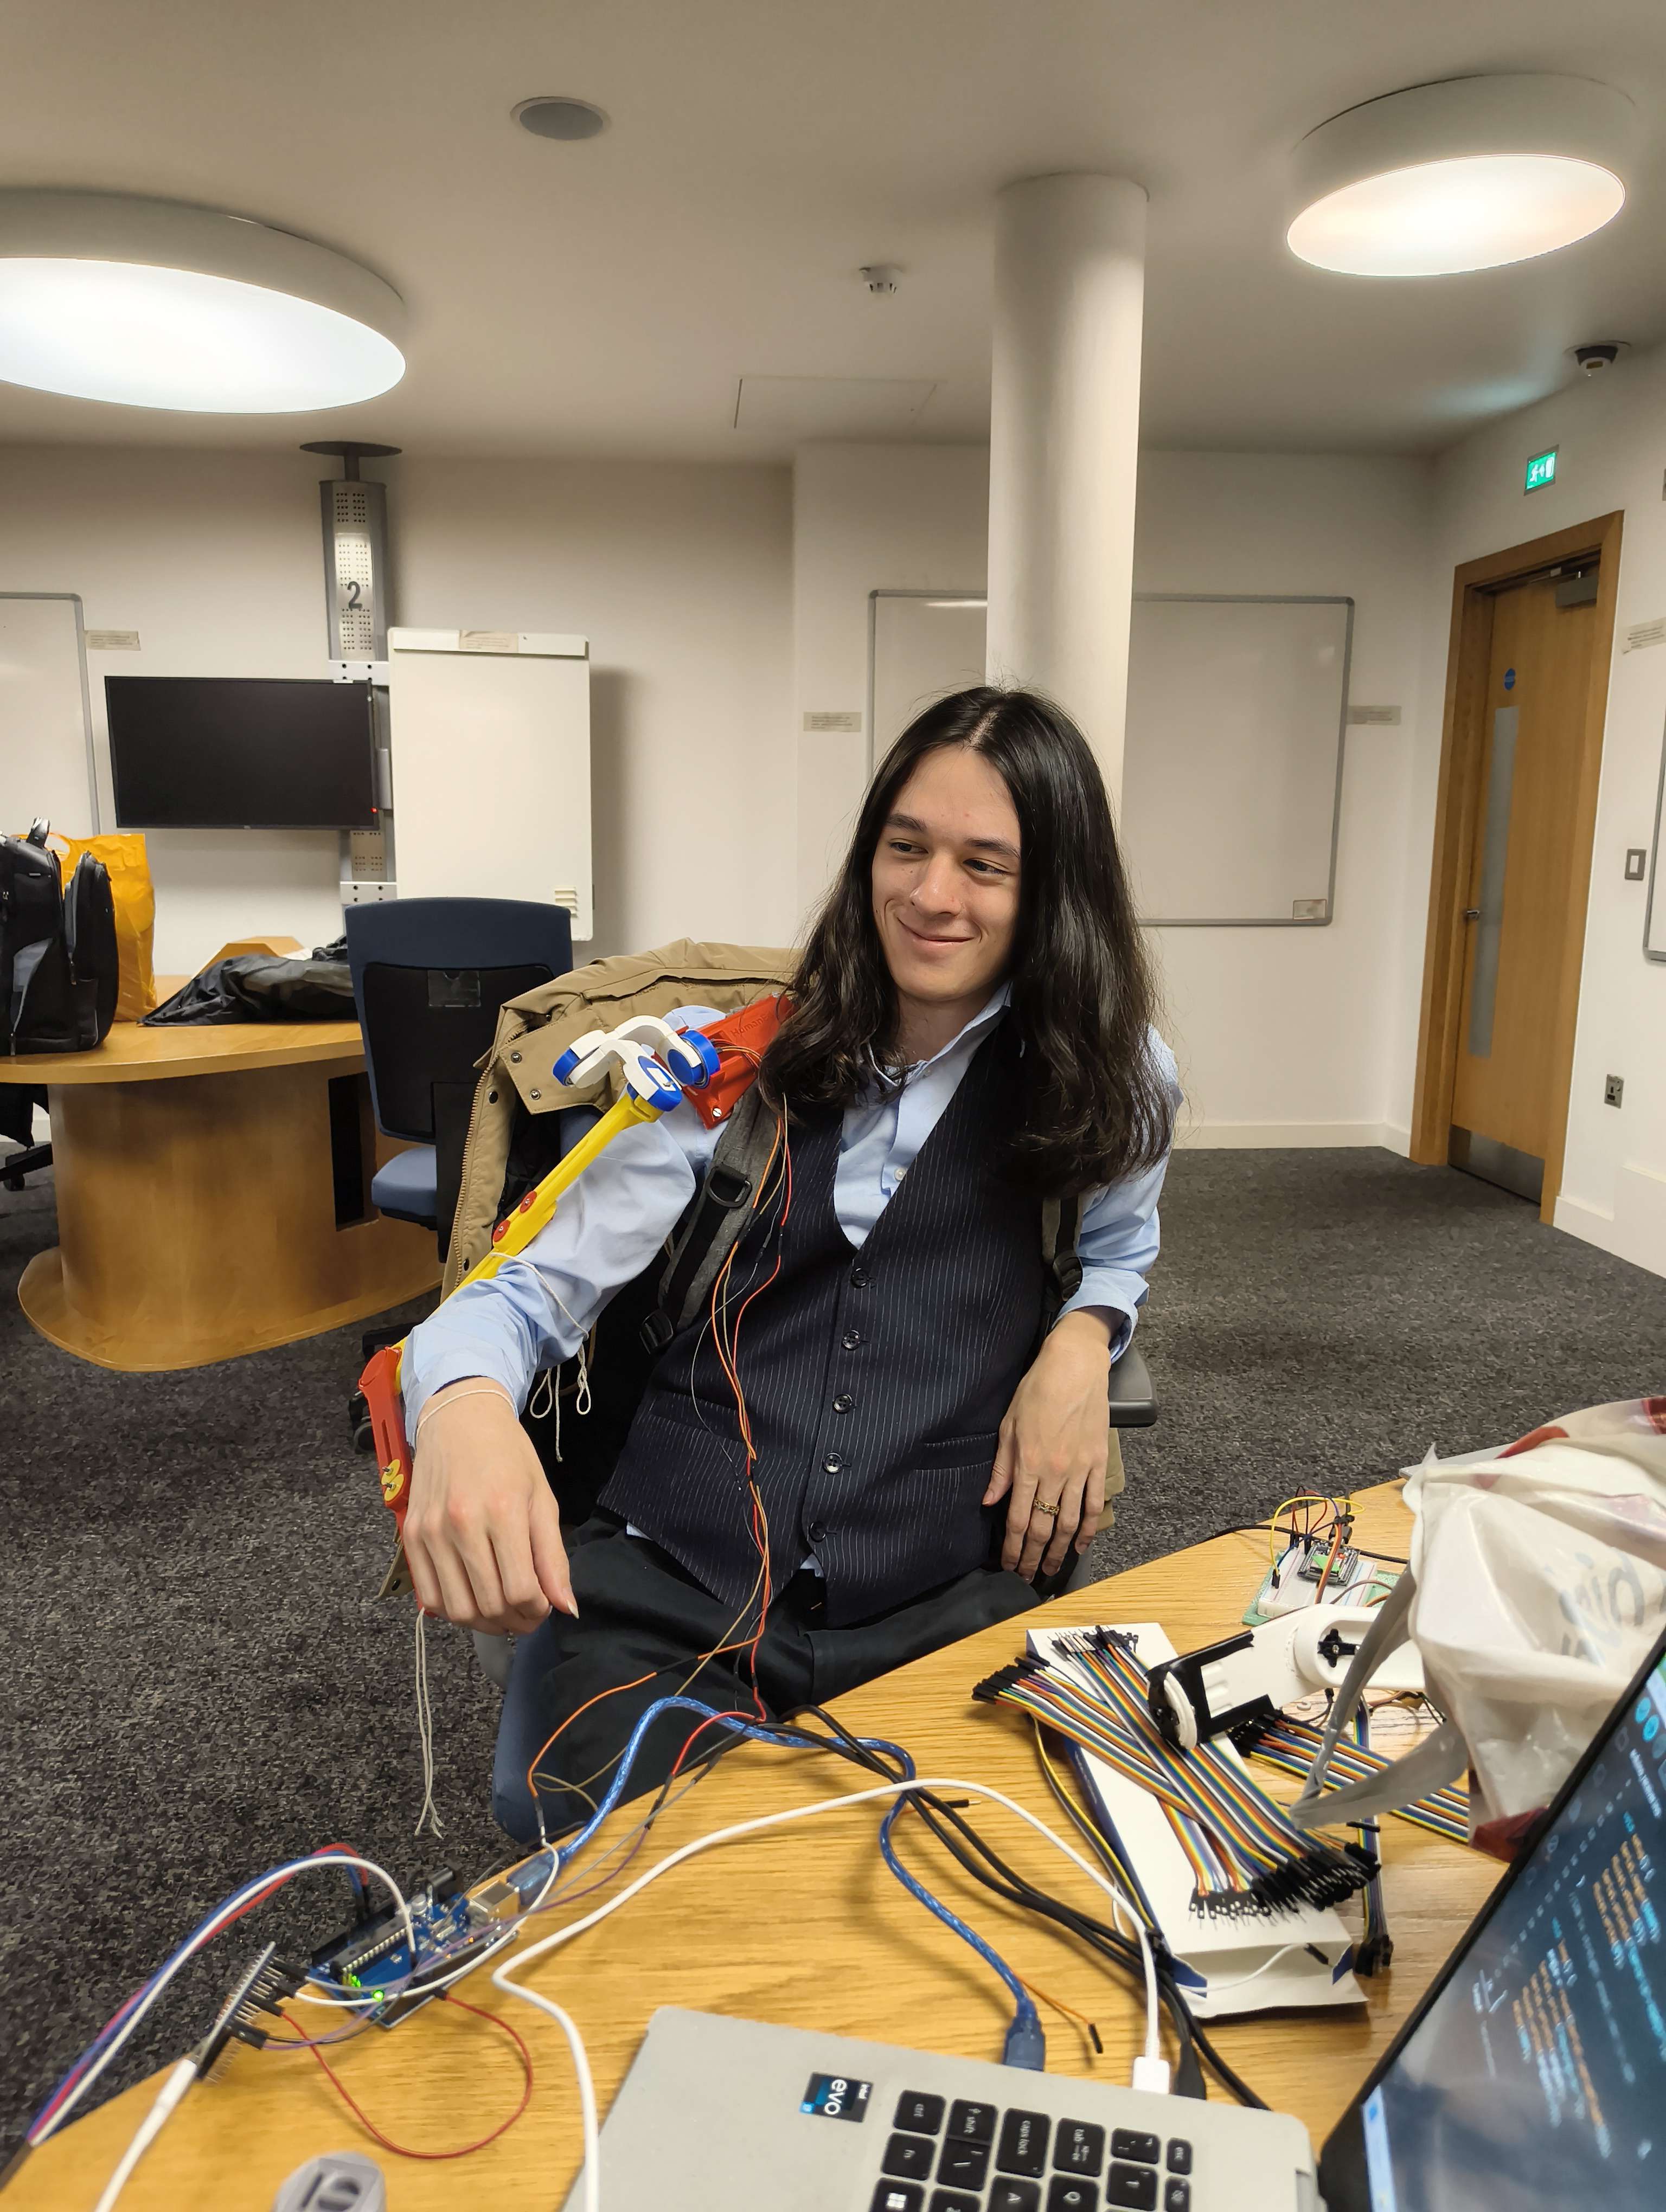
The Exoskeleton Team is currently working on a Teleoperations system which will allow a user to remotely control a robot over Wi-Fi using their own arms. This project is aimed at assisted lifting and hazardous materials handling.
CAD
3D Printing
Electronics
Programming
Simulation
AI / ML
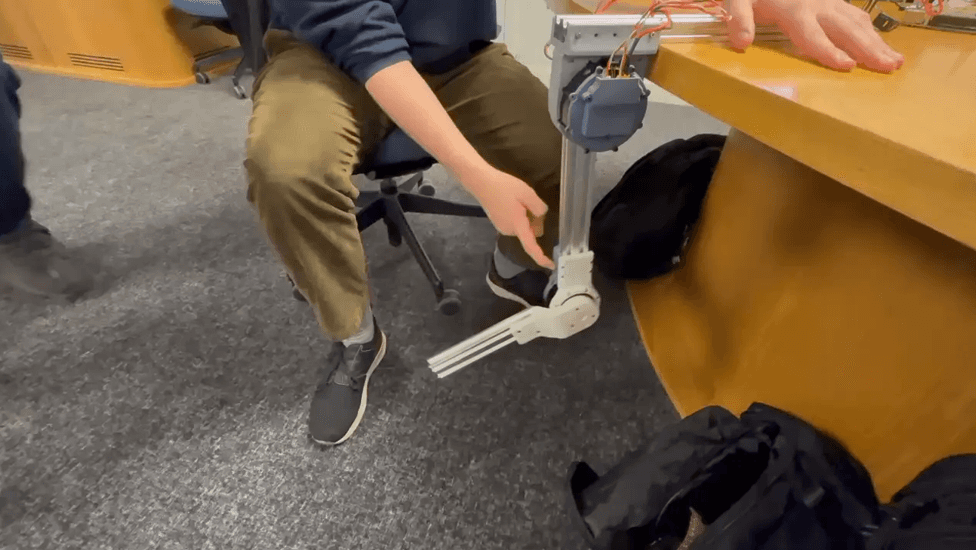
Actuator testing.